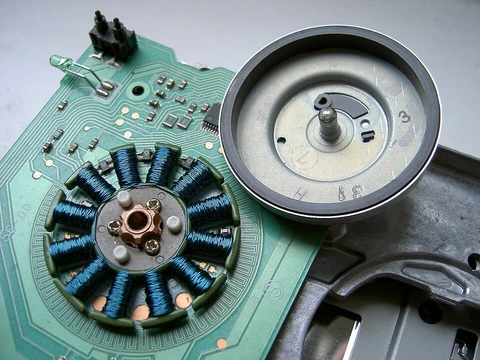
Ultrasonic motor
Ultrasonic motors use resonant vibration to drive rotors or sliders.

Yorkshire Terrier · Public domain
An ultrasonic motor is a piezoelectric motor that works by using ultrasonic vibrations in a part called the stator, which presses against a rotor (for rotation) or a slider (for linear motion). Like other piezoelectric motors, it typically relies on a piezoelectric material—most often lead zirconate titanate, and sometimes lithium niobate or other single-crystal materials. What sets ultrasonic motors apart is their use of resonance to boost the stator’s vibration against the rotor. They can also achieve unlimited rotation or sliding distances, whereas standard piezoelectric actuators are constrained by the static strain the piezoelectric element can handle.
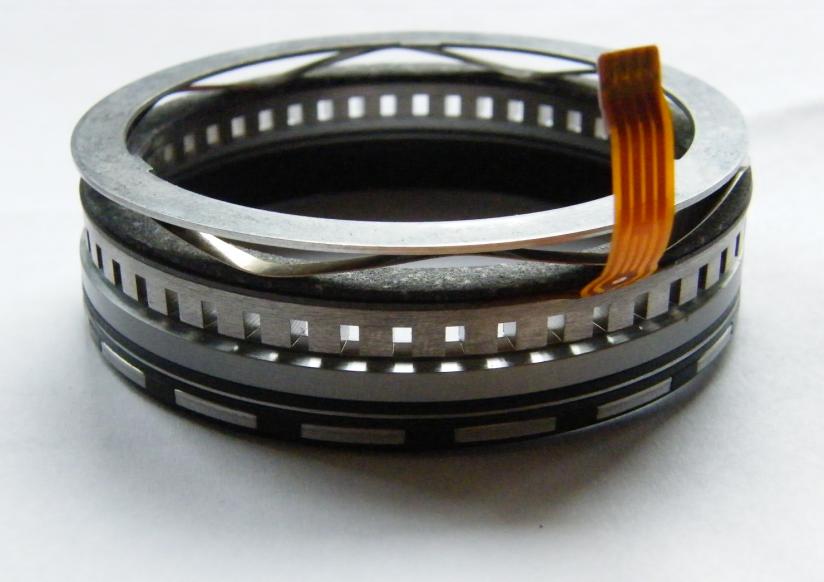
A common use for ultrasonic motors is in camera lenses, where they move lens elements for autofocus. They replace the noisier and often slower micro-motors found in earlier systems.
**Mechanism**
Dry friction is usually at play in the contact between stator and rotor. The ultrasonic vibration in the stator does two things: it drives the rotor’s motion and adjusts the frictional forces at the interface. This friction control is essential—without it, the rotor couldn’t move beyond a single vibration cycle, and the motor wouldn’t work.
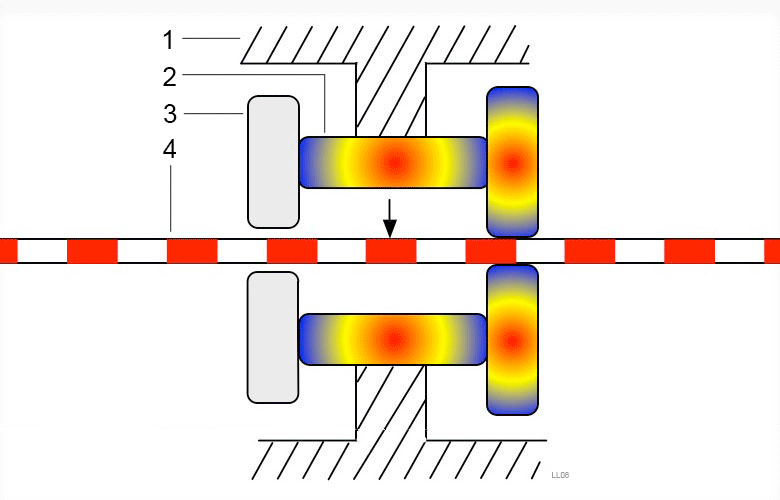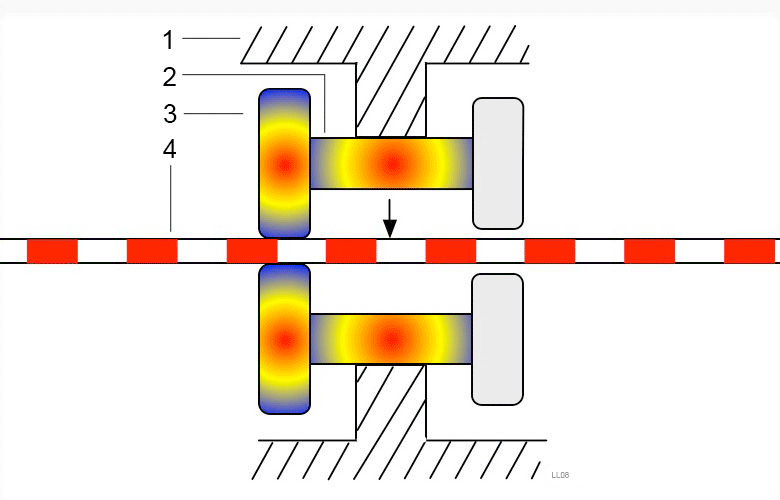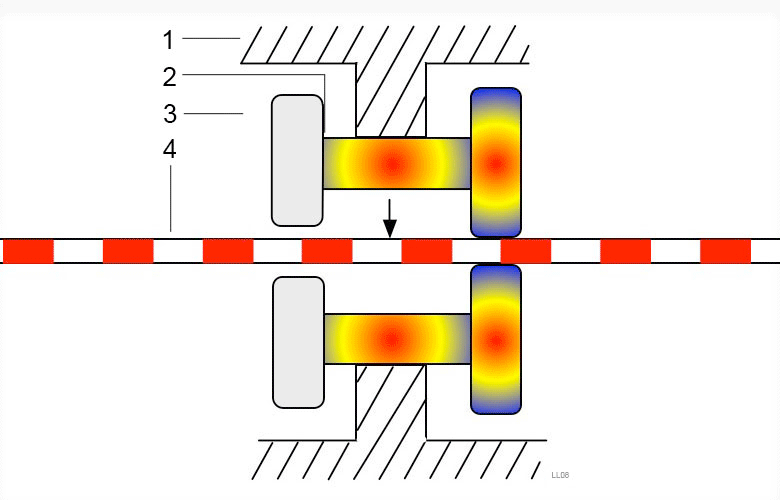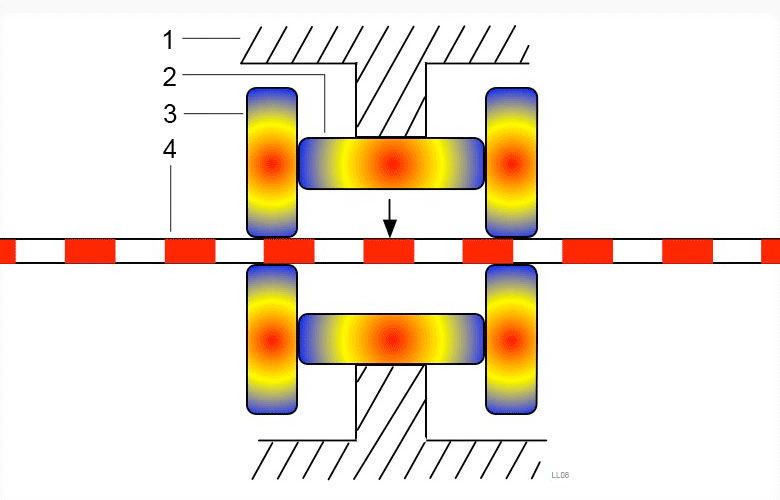
There are two main ways to manage friction along the stator-rotor contact: traveling-wave vibration and standing-wave vibration. Some of the earliest practical motors, like those developed by Sashida in the 1970s, used standing-wave vibration with angled fins on the contact surface. These motors worked but only rotated in one direction. Later designs by Sashida and researchers at Matsushita, ALPS, and Canon adopted traveling-wave vibration to allow bi-directional motion, which also improved efficiency and reduced wear on the contact interface. A special high-torque “hybrid transducer” ultrasonic motor combines circumferentially-poled and axially-poled piezoelectric elements to produce both axial and torsional vibration at the contact interface—a driving method that falls somewhere between standing-wave and traveling-wave approaches.
A key insight in ultrasonic motor research is that the maximum vibration a structure can handle tends to occur at a roughly constant vibration velocity, no matter the frequency. Vibration velocity is the rate of change of displacement over time, not the speed of wave propagation through the material.
- Peak vibration velocity
- around 1 m/s
- Frequency threshold for inaudibility
- 20 kHz
- Example low frequency
- 50 Hz
- Example high frequency operation
- 50 MHz surface acoustic wave (SAW)
- Vibration displacement at 50 hz
- about 10 mm
- Vibration displacement at 20 khz
- tens of micrometers
- Vibration displacement at 50 mhz
- a few nanometers
Lore & Background
Dry friction is often used in contact, and the ultrasonic vibration induced in the stator is used both to impart motion to the rotor and to modulate the frictional forces present at the interface. The friction modulation allows bulk motion of the rotor (i.e., for farther than one vibration cycle); without this modulation, ultrasonic motors would fail to operate. Two different ways are generally available to control the friction along the stator-rotor contact interface, traveling-wave vibration and standing-wave vibration. Some of the earliest versions of practical motors in the 1970s, by Sashida, for example, used standing-wave vibration in combination with fins placed at an angle to the contact surface to form a motor, although one that rotated in a single direction. Later designs by Sashida and researchers at Matsushita, ALPS, and Canon made use of traveling-wave vibration to obtain bi-directional motion, and found that this arrangement offered better efficiency and less contact interface wear. An exceptionally high-torque 'hybrid transducer' ultrasonic motor uses circumferentially-poled and axially-poled piezoelectric elements together to combine axial and torsional vibration along the contact interface, representing a driving technique that lies somewhere between the standing and traveling-wave driving methods.
A key observation in the study of ultrasonic motors is that the peak vibration that may be induced in structures occurs at a relatively constant vibration velocity regardless of frequency. The vibration velocity is simply the time derivative of the vibration displacement in a structure, and is not (directly) related to the speed of the wave propagation within a structure. Many engineering materials suitable for vibration permit a peak vibration velocity of around 1 m/s. At low frequencies — 50 Hz, say — a vibration velocity of 1 m/s in a woofer would give displacements of about 10 mm, which is visible. As the frequency is increased, the displacement decreases, and the acceleration increases. As the vibration becomes inaudible at 20 kHz or so, the vibration displacements are in the tens of micrometers, and motors have been built that operate using 50 MHz surface acoustic wave (SAW) that have vibrations of only a few nanometers in magnitude. Such devices require care in construction to meet the necessary precision to make use of these motions within the stator.
More generally, there are two types of motors, contact and non-contact, the latter of which is rare and requires a working fluid to transmit the ultrasonic vibrations of the stator toward the rotor. Most versions use air, such as some of the earliest versions by Hu Junhui. Research in this area continues, particularly in near-field acoustic levitation for this sort of application. (This is different from far-field acoustic levitation, which suspends the object at half to several wavelengths away from the vibrating object.)
Reader's Guide
One common application of ultrasonic motors is in camera lenses where they are used to move lens elements as part of the auto-focus system. Ultrasonic motors replace the noisier and often slower micro-motor in this application. Canon was one of the pioneers of the ultrasonic motor, and made the "USM" famous in the late 1980s by incorporating it into its autofocus lenses for the Canon EF lens mount. Numerous patents on ultrasonic motors have been filed by Canon, its chief lensmaking rival Nikon, and other industrial concerns since the early 1980s. Canon has not only included an ultrasonic motor (USM) in their DSLR lenses, but also in the Canon PowerShot SX1 IS bridge camera. The ultrasonic motor is now used in many consumer and office electronics requiring precision rotations over long periods of time. The technology has been applied to photographic lenses by a variety of companies under different names. The significance of the ultrasonic motor lies in its ability to provide quiet, precise motion with arbitrarily large travel distances, enabled by resonant vibration and friction modulation, making it a key component in modern autofocus systems and other precision devices.
Did You Know?
- Ultrasonic motors use resonance to amplify the vibration of the stator in contact with the rotor.
- The peak vibration velocity in many engineering materials is around 1 m/s, regardless of frequency.
- Some of the earliest practical ultrasonic motors in the 1970s were built by Sashida using standing-wave vibration.
Fundamental Operating Principle
An ultrasonic motor is a piezoelectric device in which a vibrating stator drives a rotor or slider through dry friction at their contact interface. The stator's vibration is amplified by resonance, which distinguishes this class of motor from other piezoelectric actuators that rely on static strain limited by the material's deformation capacity. Because resonance is the driving mechanism, ultrasonic motors can deliver arbitrarily large rotational or linear travel, unbounded by the tiny displacements a piezoelectric crystal can sustain on its own. The most frequently used piezoelectric material is lead zirconate titanate, though single-crystal alternatives such as lithium niobate appear in some designs. The critical insight behind the mechanism is that the ultrasonic vibration does double duty: it both pushes the rotor and continuously modulates the frictional force at the stator-rotor interface. Without this friction modulation, the rotor would merely oscillate in place over a single vibration cycle rather than achieving sustained bulk motion. This dual role of vibration as both energy source and friction controller is what makes the device function as a motor rather than a simple actuator.
Vibration Physics Across the Frequency Spectrum
A remarkable observation in ultrasonic motor research is that the peak vibration velocity achievable in a structure remains roughly constant regardless of the operating frequency. This velocity, defined as the time derivative of displacement, is independent of how fast the wave itself propagates through the material. For many engineering-grade materials, the practical ceiling sits near one meter per second. At a low frequency such as fifty hertz, that velocity corresponds to a displacement of roughly ten millimeters—easily visible to the naked eye, as in a loudspeaker woofer. As frequency climbs, displacement shrinks while acceleration grows. By the time vibration enters the ultrasonic range around twenty kilohertz, displacements have fallen to the tens of micrometers. Pushing further, surface acoustic wave devices operating at fifty megahertz produce stator vibrations of only a few nanometers. Such extreme miniaturization of motion demands extraordinary precision in fabrication and assembly to ensure the rotor can still extract useful work from those nanoscale oscillations.
Industrial Adoption and the Canon Legacy
Canon stands as the most prominent industrial champion of ultrasonic motor technology. Beginning in the late 1980s, the Japanese camera maker integrated these motors into its EF-mount autofocus lenses, branding the technology USM and turning it into a widely recognized product feature. The ultrasonic motor replaced the older micro-motor in lens autofocus systems, offering quieter and faster operation for photographers. Canon's commitment extended beyond DSLR lenses; the company also embedded the technology in the PowerShot SX1 IS bridge camera, demonstrating its versatility across product lines. Canon's chief lensmaking rival Nikon, along with other industrial concerns, filed numerous patents on ultrasonic motors starting in the early 1980s, signaling broad commercial interest. The earliest documented patent traces back to a 1965 application by Lavrinenko and Necrasov, with subsequent US patents appearing in 1975 and 1982. Today, the technology has been adopted by a variety of manufacturers under different trade names, and ultrasonic motors find their way into consumer electronics and office equipment wherever precision rotation over extended periods is required.
Wave-Driving Schemes and Contact Topologies
Engineers have developed several distinct strategies for driving the stator vibration that ultimately moves the rotor. The earliest practical motors, built by Sashida in the 1970s, employed standing-wave vibration combined with fins angled relative to the contact surface; however, this arrangement could only rotate in a single direction. Later work by Sashida and researchers at Matsushita, ALPS, and Canon shifted toward traveling-wave vibration, which enabled bi-directional motion and delivered improved efficiency along with reduced wear at the stator-rotor interface. A more exotic approach, the hybrid transducer, pairs circumferentially-poled and axially-poled piezoelectric elements to superimpose axial and torsional vibrations at the contact, occupying a middle ground between the standing and traveling-wave methods while producing exceptionally high torque. Beyond wave type, motors also differ in whether they are contact or non-contact devices. Non-contact versions are rare and require a working fluid—typically air—to transmit ultrasonic vibrations from stator to rotor. Some of the earliest such designs are attributed to Hu Junhui, and research continues in near-field acoustic levitation, a regime distinct from far-field levitation where the object is suspended at half to several wavelengths from the source.
Gallery
More in Electric Motors, Part 3 1-24
Spotted an error? Know more?
Reader corrections go straight into our review queue. Suggest an edit · How this site is sourced