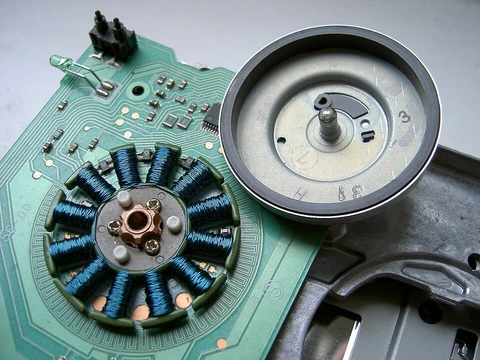
Switched reluctance linear motor
A magnet-free linear motor using variable reluctance for force generation.

Switched reluctance linear motors (SRLMs), also known as linear switched reluctance motors (LSRMs), variable reluctance linear motors, or switched reluctance linear machines, are a type of electric machine that work based on the principle of a varying magnetic reluctance for force generation. They consist of an active part (primary) containing windings and a passive (secondary) part, and can be used in reverse mode as a Switched Reluctance Linear Generator. Notable for not requiring permanent magnets, which are considered scarce materials, SRLMs are gaining traction in linear applications due to their simplicity, robustness, economic rationality, and high fault tolerance compared to linear synchronous and linear induction motors.
- First switched reluctance motor invented
- 1838
- Inventor of first switched reluctance mo
- W. H. Taylor
- Country of first invention
- United States
- First srlm ideas date
- 1970s
- First srlm patent year
- 1973
- First srlm patent inventors
- Hi D Chai and Joseph P Pawletko
- First srlm patent assignee
- International Business Machines Corp
Lore & Background
The first switched reluctance motor was invented in 1838 by W. H. Taylor in the United States, initially designed to propel locomotives. In the 1920s, the synchronous reluctance motor was invented, using a specially designed cageless rotor to eliminate rotor losses. The switched reluctance motor initially suffered from a lack of effective speed control until the 1970s, when fast-switching electronics within variable speed drives allowed it to reach performances comparable to conventional induction and permanent magnet motors. The first switched reluctance linear motor ideas date back to the 1970s, with a 1973 patent by Hi D Chai and Joseph P Pawletko from International Business Machines Corp for a 'Variable reluctance linear stepper motor,' followed by a linear stepper motor for serial printer applications. In 1977, J.W. Finch researched the Linear Vernier Reluctance Stepper Motor to replace a mechanical conveyor for a trolley. In 1988-89, Takamaya developed a linear motor based on variable reluctance. Patent proposals emerged in 1995 from Matsukawa Koji and Saito Jin at Matsushita Electric Works Ltd for an automatic door opening-closing device to reduce driving force ripple. In the XXIst century, the technology was validated in on-site pilot projects like the SeaTitan, developed by Wedge Global with research at CIEMAT in Spain.
Reader's Guide
The switched reluctance linear motor is significant for its magnet-free design, enabling deployment over long distances without reliance on scarce permanent magnet materials. Its method of operation requires no relative motion for force production, allowing it to hold position indefinitely, unlike linear induction motors. This makes it particularly suitable for conveyor operations. The article describes applications including the HyperTrack project led by Zeleros in the Port of Sagunto, Spain, in collaboration with CIEMAT, which evaluated SRLM performance for hyperloop and cargo port mover applications. In renewable energy, the SeaTitan project under Horizon 2020 demonstrated SRLMs in direct-drive power take-off systems for wave and tidal energy converters, aiming to reduce the levelized cost of energy for marine applications. SRLMs have also been applied in industrial linear actuators for precision manufacturing and automation, and are under exploration for electromagnetic launch systems such as aircraft carrier catapults. The technology's legacy lies in its validation through pilot projects and its potential for clean energy generation and high-speed transportation, supported by industrial stakeholders including ArcelorMittal and Valenciaport.
Did You Know?
- SRLMs do not require permanent magnets, which are considered a scarce material, enabling deployment over long distances.
- The SeaTitan project, funded under Horizon 2020, demonstrated SRLMs for direct-drive wave and tidal energy converters without rare-earth materials.
Operating Principles & Design Fundamentals
The switched reluctance motor operates on a fundamentally different principle than conventional wound-rotor machines. Its rotor contains no windings whatsoever; instead, it is fabricated from soft magnetic material such as laminated silicon steel, shaped with multiple projecting lobes that function as salient magnetic poles. The stator, by contrast, carries the electromagnet windings on its own set of projecting poles, a layout reminiscent of a wound-field brushed DC motor. Torque arises purely from the magnetic reluctance effect: when a stator pole is energized, the nearest rotor lobe is drawn from its fully unaligned position—the point of maximum magnetic reluctance—toward alignment with the stator field, where reluctance is minimized. To keep the rotor turning, the energized stator field must continuously lead the rotor poles, perpetually pulling them forward. In most switched reluctance designs the rotor carries fewer poles than the stator, a choice that reduces torque ripple and avoids the degenerate condition in which every pole aligns at once, producing zero usable torque. A persistent engineering difficulty is that each phase winding's inductance shifts with rotor position because the magnetic circuit's reluctance changes, making the control problem inherently nonlinear.
Control Evolution & Technological Enablers
For much of the twentieth century, the switched reluctance motor remained a laboratory curiosity rather than a production workhorse, largely because the electronics needed to sequence its stator phases were too complex and too expensive to manufacture at scale. The breakthrough came with the maturation of large-scale integrated circuits, which brought embedded microcontrollers to a price point that made real-time commutation practical. Modern drives now run sophisticated algorithms on these microcontrollers, continuously sampling rotor position along with current and voltage feedback, and then shaping the drive waveform phase by phase to match the instantaneous magnetic geometry. This electronic commutation is what gives the switched reluctance family its principal operational advantages: reliable starting from standstill, precise speed regulation, and markedly reduced torque ripple compared with earlier open-loop approaches. The availability of computer design tools and advances in electromagnetic theory further lowered the barrier, allowing engineers to optimize pole geometry and winding layout iteratively. The result is a motor architecture whose control complexity, once the dominant cost driver, has been absorbed into inexpensive silicon, unlocking the machine's inherent power-density and cost benefits for a far wider range of industrial and consumer uses.
Synchronous Reluctance Variant & Material Innovation
The synchronous reluctance motor pairs an equal number of stator and rotor poles—always an even count, most commonly four or six. The rotor lobes are sculpted with internal flux barriers, small holes that channel flux along the direct axis, creating torque-producing anisotropy without embedded magnets or windings. Because the rotor carries no current-conducting elements, its losses are far lower than an induction motor's, though the trade-off is typically a lower torque rating. Once at synchronous speed, the machine can run on sinusoidal voltage, with speed adjustment handled by a variable-frequency drive. High-power designs have historically relied on rare-earth magnets such as neodymium and dysprosium. A 2023 study demonstrated an alternative: a dual-phase magnetic laminate in which magnetization creates strongly magnetized regions serving as rotor poles while leaving adjacent regions nonpermeable. In one test using high-temperature nitriding for added strength, the dual-phase rotor delivered 23 kW at 14,000 RPM with 94 percent peak efficiency, whereas a comparable conventional rotor managed only 3.7 kW. The nonpermeable posts and bridges can be made larger and stronger, reducing flux-line interference between rotor and stator. The principal limitation is a magnetization ceiling of 1.5 tesla, below the roughly 2 tesla of conventional magnets.
Applications & Practical Trade-offs
The reluctance motor family spans several subtypes—synchronous, variable, switched, and variable stepping—each tuned to different operating regimes. Their collective appeal lies in delivering high power density at low manufacturing cost, a combination that makes them attractive across a remarkably wide application spectrum. In practice, however, the architecture carries two well-known drawbacks: pronounced torque ripple, defined as the gap between peak and minimum torque over a single revolution, which is most severe at low speed, and the audible noise that ripple generates. These characteristics have shaped where the technology thrives. Reluctance motors appear in analog electric meters and clocks, in certain washing machine designs, in hard disk drive motors, and in power tools such as drill presses, lathes, and bandsaws. More demanding applications include the control rod drive mechanisms of nuclear reactors and propulsion in electric vehicles. A closely related machine, the flux switching alternator, exploits a similar stator-rotor arrangement but operates as a generator rather than a motor. The breadth of this application list—from precision timing devices to reactor safety systems—underscores how the combination of simplicity, cost-effectiveness, and robust power delivery has made reluctance principles a persistent thread in electrical machine design.
More in Electric Motors, Part 3 1-24
Spotted an error? Know more?
Reader corrections go straight into our review queue. Suggest an edit · How this site is sourced