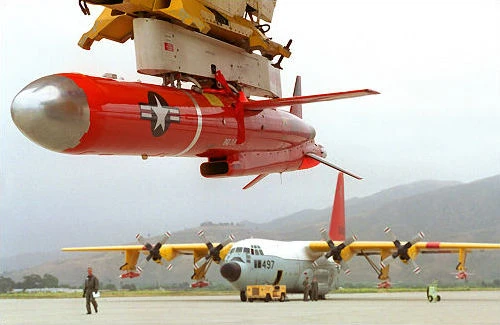
Boeing YQM-94 B-Gull
Developmental high-altitude reconnaissance drone with runway takeoff and landing.

The Boeing YQM-94 B-Gull (designated Compass Cope B) was an experimental reconnaissance drone. It could operate from runways like a piloted aircraft, staying aloft for up to 24 hours at high altitude to conduct surveillance, relay communications, or sample the atmosphere.
The Compass Cope program began in 1971 when the U.S. Air Force sought a new drone with runway takeoff and landing, high-altitude endurance, and multi-mission capability. Boeing was initially chosen as the sole contractor and received a contract for two YQM-94A (later YGQM-94A) demonstrators that year. Ryan Aeronautical then proposed an alternative, and in 1972 the Air Force awarded Ryan a contract for two YQM-98A (later YGQM-98A) demonstrators as well.
The YQM-94A was a cantilever shoulder-wing monoplane, essentially a jet-powered sailplane. It had long straight wings, a twin tail, retractable tricycle landing gear, and a turbojet housed in a pod on its back. The engine was a General Electric YJ97-GE-100 producing 5,270 pounds of thrust. The airframe used aluminum and fiberglass; the lower half of the circular fuselage was glass-fiber honeycomb, the same material used for radomes. The wings were aluminum-skinned honeycomb with a fiberglass core that insulated the fuel tanks from the extreme cold at high altitudes.
As a demonstrator, the YQM-94A used off-the-shelf components to cut costs. Its datalink was based on the AN/TPW-2A X-band radar, and its flight control system came from the Sperry Corporation system used on the Beechcraft QU-22B Pave Eagle. The drone was controlled remotely from the ground with no autonomous guidance; a nose-mounted television camera let a ground pilot fly it. The landing gear came from a Rockwell Commander. Because the YQM-94’s fuselage sat lower than the Commander’s, Boeing used this as a lift-dumping system: as the aircraft settled onto its strengthened nose wheel, the wing was placed at a negative angle of attack.
The remote control system was tested over ten months using a Cessna 172, chosen because its approach speed and wing loading were similar to the YQM-94’s. By the end of 1971, the system had been tested in 150 flights with eight different remote pilots. Ninety of those flights occurred at night using a low-light television system.
Quick Facts
- Manufacturer
- Boeing
- First Flight
- 28 July 1973
- Primary User
- United States Air Force
Facts from the source article.
Lore & Background
The Compass Cope program was initiated by the United States Air Force in 1971 to develop an upgraded reconnaissance drone. Boeing was originally selected as a sole source and awarded a contract for two YQM-94A demonstrators. However, Ryan Aeronautical pitched an alternative, the YQM-98A Compass Cope R, and received a contract for two demonstrators the following year. The YQM-94A was constructed using aluminum and fiberglass, with the lower half of the fuselage made of glass-fiber honeycomb. Its wings were aluminum-skinned honeycomb with a fiberglass core that insulated the fuel tanks from the cold at high altitudes. As a demonstrator, it used off-the-shelf components to reduce costs, including a datalink based on the AN/TPW-2A X-band radar and a flight control system derived from the Sperry Corporation system used on the Beechcraft QU-22B Pave Eagle. The aircraft was controlled remotely from the ground with no autonomous guidance capability, using a television camera in the nose for remote piloting. The undercarriage came from a Rockwell Commander, and Boeing used a lift-dumping system that placed the wing at a negative angle of attack as the aircraft settled on its strengthened nose wheel. The remote control system was tested using a Cessna 172 over ten months, with 150 flights using eight different remote pilots, 90 of which occurred at night. A safety check pilot was on board the Cessna and took manual control on three occasions to avoid collisions or during system failures.
Reader's Guide
The Boeing YQM-94 B-Gull was one of two competing designs in the USAF's Compass Cope program, which sought a runway-operable, high-endurance reconnaissance drone. Its development highlighted the challenges of early remotely piloted aircraft, including the loss of the first prototype on its second flight due to an electrical short circuit from damaged mylar insulation, which caused erroneous rudder signals compounded by an incorrect airspeed indication and a wing imbalance. The second demonstrator completed the evaluation program, achieving a 17-hour 24-minute endurance flight above 55,000 feet. Although Boeing won the competition in August 1976 on the basis of lower cost and was awarded a contract for preproduction YQM-94B prototypes, Ryan challenged the award, noting the YQM-98's superiority in some respects. The entire Compass Cope program was cancelled in July 1977, apparently due to difficulties in developing sensor payloads. The surviving YQM-94 demonstrator was retired to the National Museum of the United States Air Force in September 1979. The B-Gull's legacy lies in its demonstration of long-endurance, high-altitude drone operations from conventional runways, a concept that influenced later UAV designs, though the program itself did not lead to operational deployment.
Did You Know?
- The first YQM-94A demonstrator crashed on its second flight on 4 August 1973 due to an electrical short circuit from damaged mylar insulation.
- The remote control system was tested using a Cessna 172 over 150 flights, 90 of which were at night.
- The YQM-94's undercarriage came from a Rockwell Commander aircraft.
More in Unmanned Aerial Vehicles by Country, Part 4 1-24
Spotted an error? Know more?
Reader corrections go straight into our review queue. Suggest an edit · How this site is sourced